🤖 AI Summary
本文使用3D高斯点云技术,基于Astrobee机器人采集的图像,实现了国际空间站内部的高效3D重建与映射。
📝 Abstract
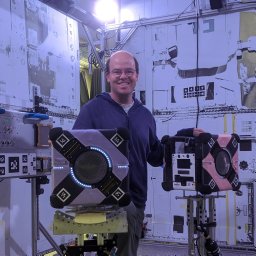
This article presents a novel 3D reconstruction and mapping of the interior of the International Space Station (ISS) using 3D Gaussian Splatting (3DGS). Using existing grayscale images from the Astrobee free-flying robot dataset, we construct a full 3D splat of the ISS' Kibō or Japanese Experiment Module (JEM). 3DGS has in recent years shown promise in providing novel view synthesis of scenes captured from many images or videos, this article applies this approach to human spaceflight systems. We compare our 3DGS architecture to existing methods such as Nerfacto and TensoRF and show that reconstruction improves the state-of-the-art in both scene quality and rendering speed. We show that with as little as 500 in-situ images, a high-fidelity map can be constructed using Astrobee's Navigation Camera (NavCam) during free-flight in the JEM. These reconstructions could enable free-flyers to rapidly create and update interior maps for intra-vehicular habitats like the ISS.